Features
Organised around the things you will run into. Every section maps to a page in the software.
Virtual device engine
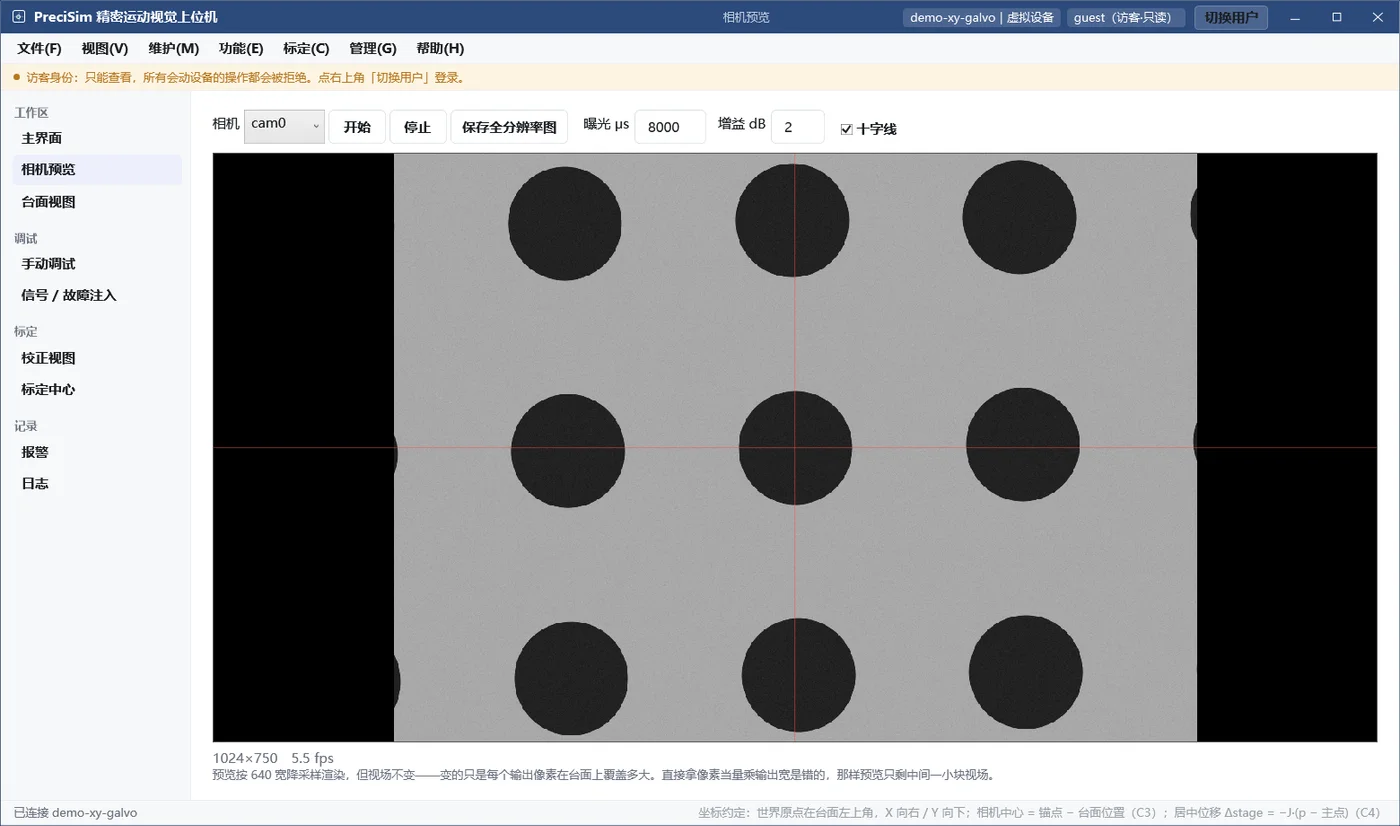
A virtual camera (exposure, gain, noise, distortion, defocus), virtual axes (accel/decel profiles, backlash, pitch error, limits), virtual IO and lighting. Every error parameter is configurable, so you can exaggerate one until a trainee sees what it does.
- Camera: resolution, pixel size, lens distortion, depth of field, noise model
- Axes: trapezoidal / S-curve motion, backlash, pitch error, repeatability
- IO: cylinder position signals, light curtain, e-stop, with configurable delays
- Galvo: field distortion, jump delay, mark delay
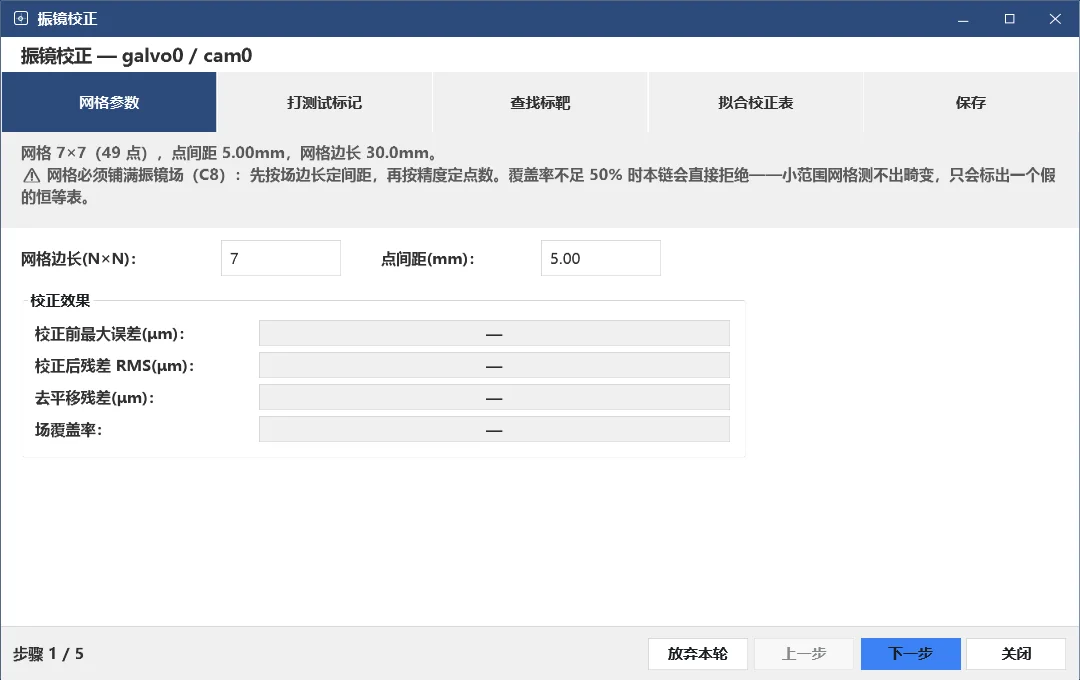
Calibration chains with ground-truth scoring
All seven chains implement one interface, each declaring its own steps and prerequisites, so the wizard, progress, cancel and archive are shared. The virtual device knows the true values, so every chain ends with measured value, true value, deviation, tolerance and verdict.
- Any step can be re-run on its own, no starting over
- Results are versioned, so you can compare and roll back
- When a criterion fails it names which one and by how much
- The same procedure runs on real hardware; you just lose the truth reference
An HMI in industrial form
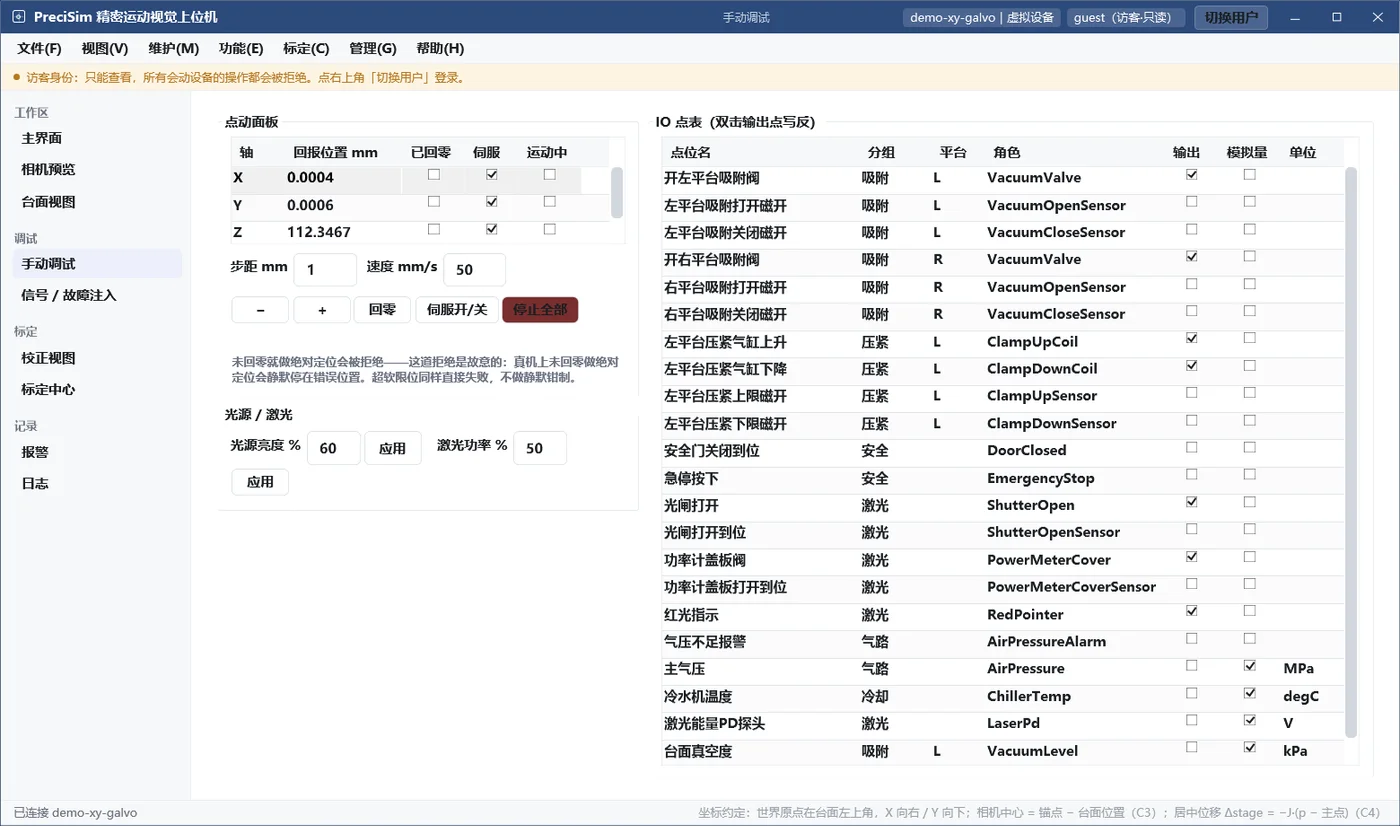
Role-based login, alarm popups with history, structured logs, recipe management, a device debug page, manual/auto mode switching. The pages a production line actually asks for.
- Roles: guest / operator / engineer / administrator
- Alarms: popup, history, exportable
- Recipes: parameter sets with change tracking
- Debug page: single-axis jog, IO forcing, live camera parameters
Workflow (Station + DAG)
A station describes its steps as a dependency graph. Adding a station or changing a sequence changes the description, not the framework.
- Step dependencies are declared, not implied
- Single-step execution and breakpoints
- One consistent retry / skip / abort policy for faults
- Execution traces export for post-mortem
Integration interfaces
Two public interfaces: vmc.dll (C API) and Modbus TCP. Drive the virtual machine from Python, C#, or from the PLC side, for automated tests or for teaching.
- vmc.dll: C-style exports, P/Invoke from any language
- Modbus TCP: a documented register map, connect a PLC directly
- Quick-start samples for Python and C#
- Interfaces are versioned; breaking changes only on a major release
Offline and intranet
School labs and factory networks usually have no internet. Offline activation codes, an offline grace period and local docs are all in the box.
- Offline activation: machine code in, activation code out, no network
- A 7–30 day grace period when online checks fail
- Docs ship with the installer for offline reading
- No personally identifiable information is collected